- COSYNE
Spiking neural network model of simultaneous localization and mapping with Spatial Semantic Pointers
Nicole Sandra-Yaffa Dumont, Terry C. Stewart, and Chris EliasmithIn Computational and Systems Neuroscience (COSYNE) 2021, Feb 2021Abstract
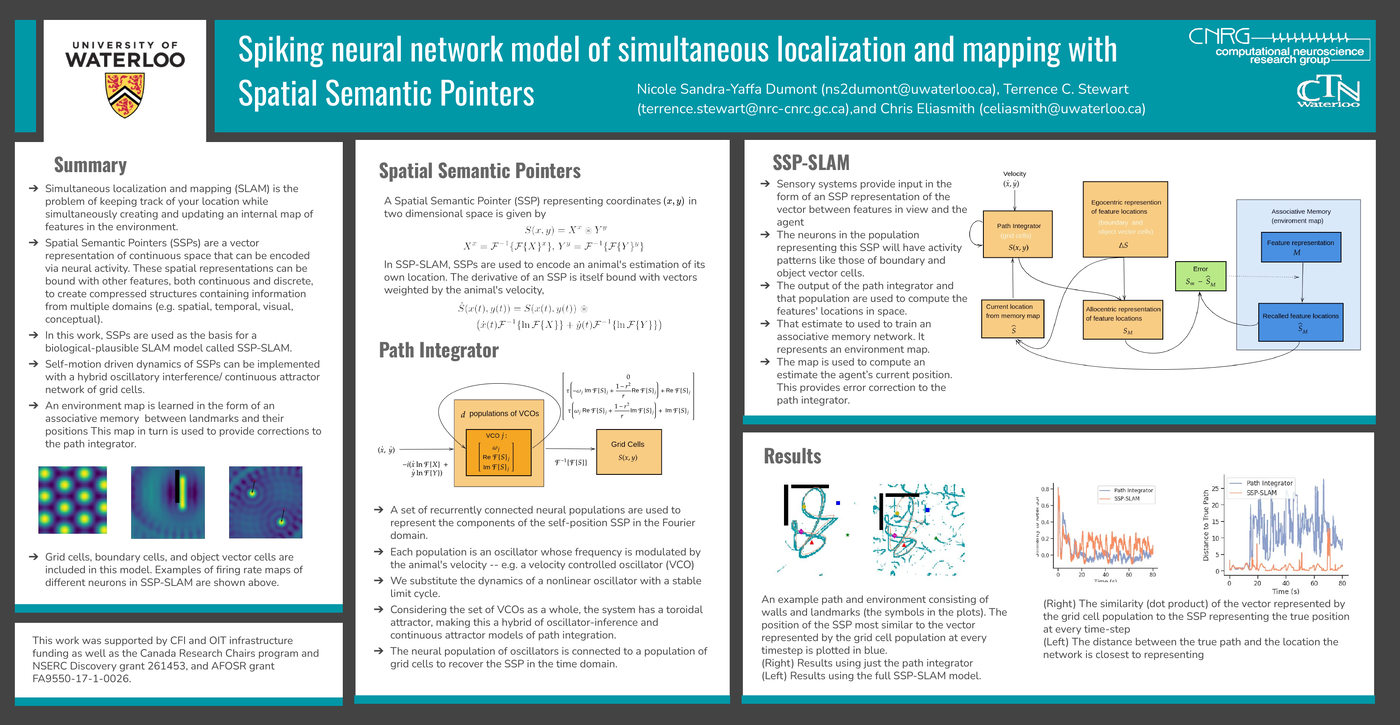
To navigate in new environments, an animal must be able to keep track of it’s own position while simultaneously creating and updating an internal map of features in the environment, a problem known as simultaneous localization and mapping (SLAM). This requires integrating information from different domains, namely self-motion cues and sensory information. Recently, Spatial Semantic Pointers (SSPs) have been proposed as a vector representation of continuous space that can be encoded via neural activity. A key feature of this approach is that these spatial representations can be bound with other features, both continuous and discrete, to create compressed structures containing information from multiple domains (e.g. spatial, temporal, visual, conceptual). In this work, SSPs are used as the basis for a biological-plausible SLAM model called SSP-SLAM. It is shown that the self-motion driven dynamics of SSPs can be implemented with a hybrid oscillatory interference/ continuous attractor network of grid cells. The estimated self position represented by this network is used for online learning of an associative memory between landmarks and their positions – i.e. an environment map. This map in turn is used to provide corrections to the path integrator. We show that environment maps can be accurately learned and can be used to greatly improved self-position estimation. Furthermore, grid cells, boundary cells, and object vector cells are included in this model.
BibTeX
@conference{dumont2021,
  author = {Dumont, Nicole Sandra-Yaffa and Stewart, Terry C. and Eliasmith, Chris},
  title = {Spiking neural network model of simultaneous localization and mapping with Spatial Semantic Pointers},
  booktitle = {Computational and Systems Neuroscience ({COSYNE}) 2021},
  year = {2021},
  address = {Online},
  month = feb,
}
